



Introduction: A Question That Starts in the Workshop
Have you ever stood by a production line and thought, why this motor keeps tripping when the load barely changes? In many of my projects, the electric motor sits at the heart of the issue—silent, misunderstood, and blamed for anything that blinks red on the dashboard. Data from small factories shows downtime linked to drive and control mismatches can eat up to 15% of productive hours in a month (true story — small losses, big headaches). So what exactly are we missing, and how do we stop repeating the same fixes that only patch symptoms?
I write this because I have seen technicians shrug and managers sign off on “good enough” solutions. We know failure modes like overheating, misaligned control loops, and inefficient torque delivery — and we feel them every time a unit idles too long. I want to share practical causes, not slogans. Later we dive into specifics: baseline numbers, user pain you probably ignore, and then some concrete ways to move forward. For now, think of this as a quick map — simple, but honest — to the problems that hide behind the sheet-metal. Next, I’ll break down where the traditional fixes stumble.
Where Traditional Solutions Fail: The Hidden Friction
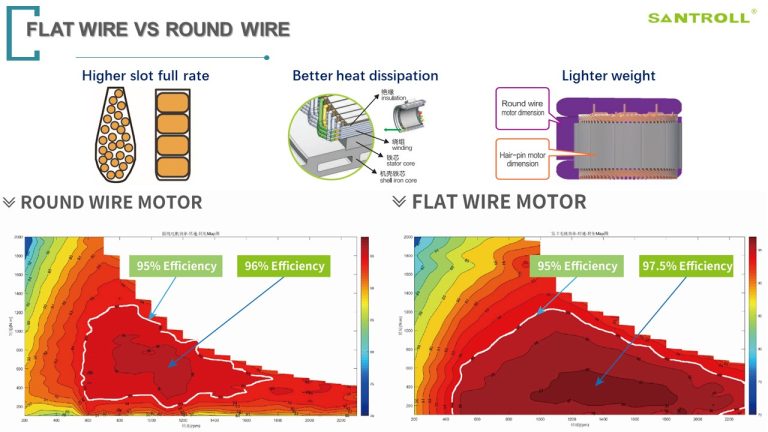
Technically speaking, a pmsm motor gives great power density and efficiency, yet many systems still underutilize those strengths due to dated integration practices. I’m not exaggerating: design choices like undersized inverters or crude control loops cause heat build-up and torque ripple — the little shakes that wear bearings and erode confidence. Field-oriented control, for instance, needs precise feedback and tuned observers; skip that and you invite stability problems. Look, it’s simpler than you think: bad matching of power converters and control firmware creates most of the recurring faults.
Why do engineers keep repeating the same mistakes?
We often default to the quickest fix: swap a motor, reset parameters, call it done. But that approach ignores the hidden user pain — unpredictable maintenance windows, creeping energy cost, and the morale hit on floor staff who keep firefighting. From my experience, the real flaw is in system-level thinking. We treat rotor and stator as black boxes, neglecting how inverter sizing, cable impedance, and thermal paths interact. The result: intermittent faults that look random but have predictable root causes. I’ve seen teams chase sensors when the problem was a mismatched inverter rating — funny how that works, right?
New Technology Principles and the Road Ahead
Let’s be forward-looking. When I evaluate upgrades now, I focus on principles that change outcomes: tighter harmonics control, adaptive control algorithms, and smarter thermal management. Adopting a modern permanent magnet synchronous motor architecture isn’t just a spec-sheet swap — it forces you to rethink power electronics, the control loop, and system monitoring. Combining better inverter designs with predictive control reduces torque ripple and extends bearing life. In short: design for interactions, not isolated specs.
Here are three practical metrics I use to evaluate whether a new motor solution will actually improve operations — think of them as a compact checklist for decision time: 1) Control bandwidth and support for field-oriented control tuning; 2) Thermal margin under worst-case duty cycles; 3) Compatibility with modern power converters and diagnostics (can you read meaningful telemetry?). Use these, and you stop buying for nameplates and start buying for uptime. I recommend starting small, pilot one line, compare mean time between failures — measurable wins matter. And yes — if you choose well, the savings show up quickly. For more real-world supplier options, I often point colleagues to Santroll as a practical partner: Santroll.
